Tin Robotics
Robotics Technology Leader · Physical AI · Motion Planning & Control

Based in Ho Chi Minh, Vietnam
I am Phan Lương Tín (Luong Tin Phan), a robotics technology leader and Chief of Revenue & Operations / Head of R&D at Next Robotics. I lead Robotics & AI Solutions, connecting research and engineering with product development, customer delivery and business growth in Vietnam, Japan and Korea.
My current research and R&D focus is Physical AI for humanoid and quadruped robots, alongside LLM-enabled interaction for service robots. Building on motion planning, real-time control and legged locomotion, I work toward intelligent robots that can operate reliably and safely in the physical world.
My experience spans autonomous mobile robots, automated parking, autonomous vehicles and multi-robot coordination. As Technical Lead at Next Robotics, I was the product owner and system architect of its Fleet Management System, taking AMR deployments from R&D to continuous industrial operation. Earlier roles at FPT Software, VinAI Research and Rapyuta Robotics shaped my approach to robotics software, system architecture and industrial safety.
I hold a Ph.D. from Sungkyunkwan University, South Korea, where I studied control strategies for a running quadruped robot with an articulated spine. Alongside my industry work, I direct automa Lab at Nguyen Tat Thanh University and teach at NTTU and the University of Greenwich Vietnam, developing courses in self-driving operating systems and motion planning.
news
latest posts
| Oct 26, 2026 | What Moving Between Industry and Academia Made Me Unlearn |
|---|---|
| Oct 18, 2026 | A Working Demo Is Not a Working System |
| Jun 15, 2025 | Run Huggingface Models Locally For Free |
selected publications
-
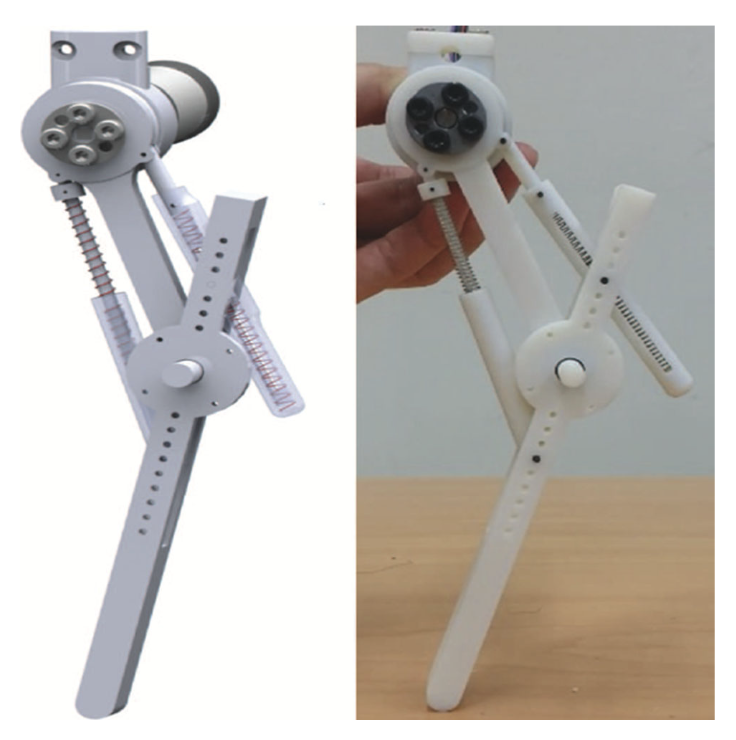 Stable running with a two-segment compliant legIntelligent Service Robotics, 2017
-
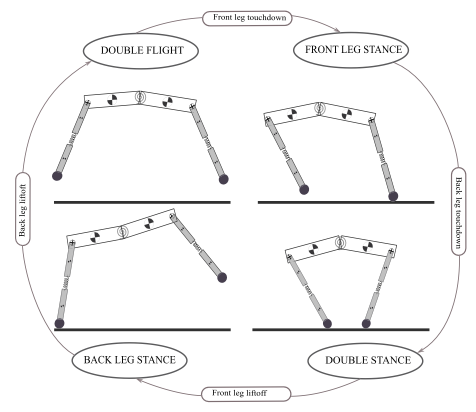 Study on effects of spinal joint for running quadruped robotsIntelligent Service Robotics, 2020
-
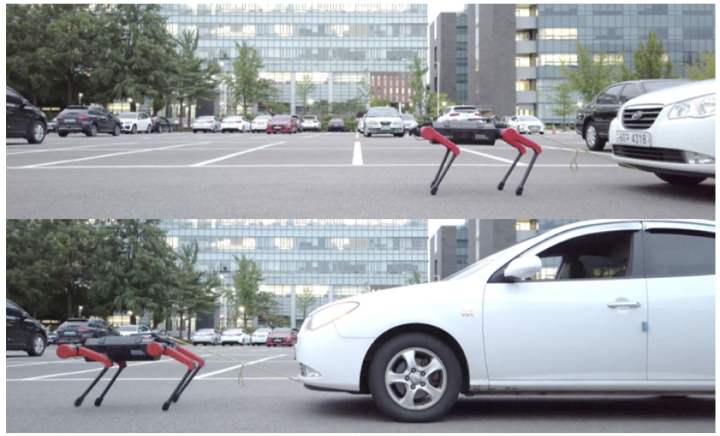 Development of a quadruped robot system with torque-controllable modular actuator unitIEEE Transactions on Industrial Electronics, 2020


